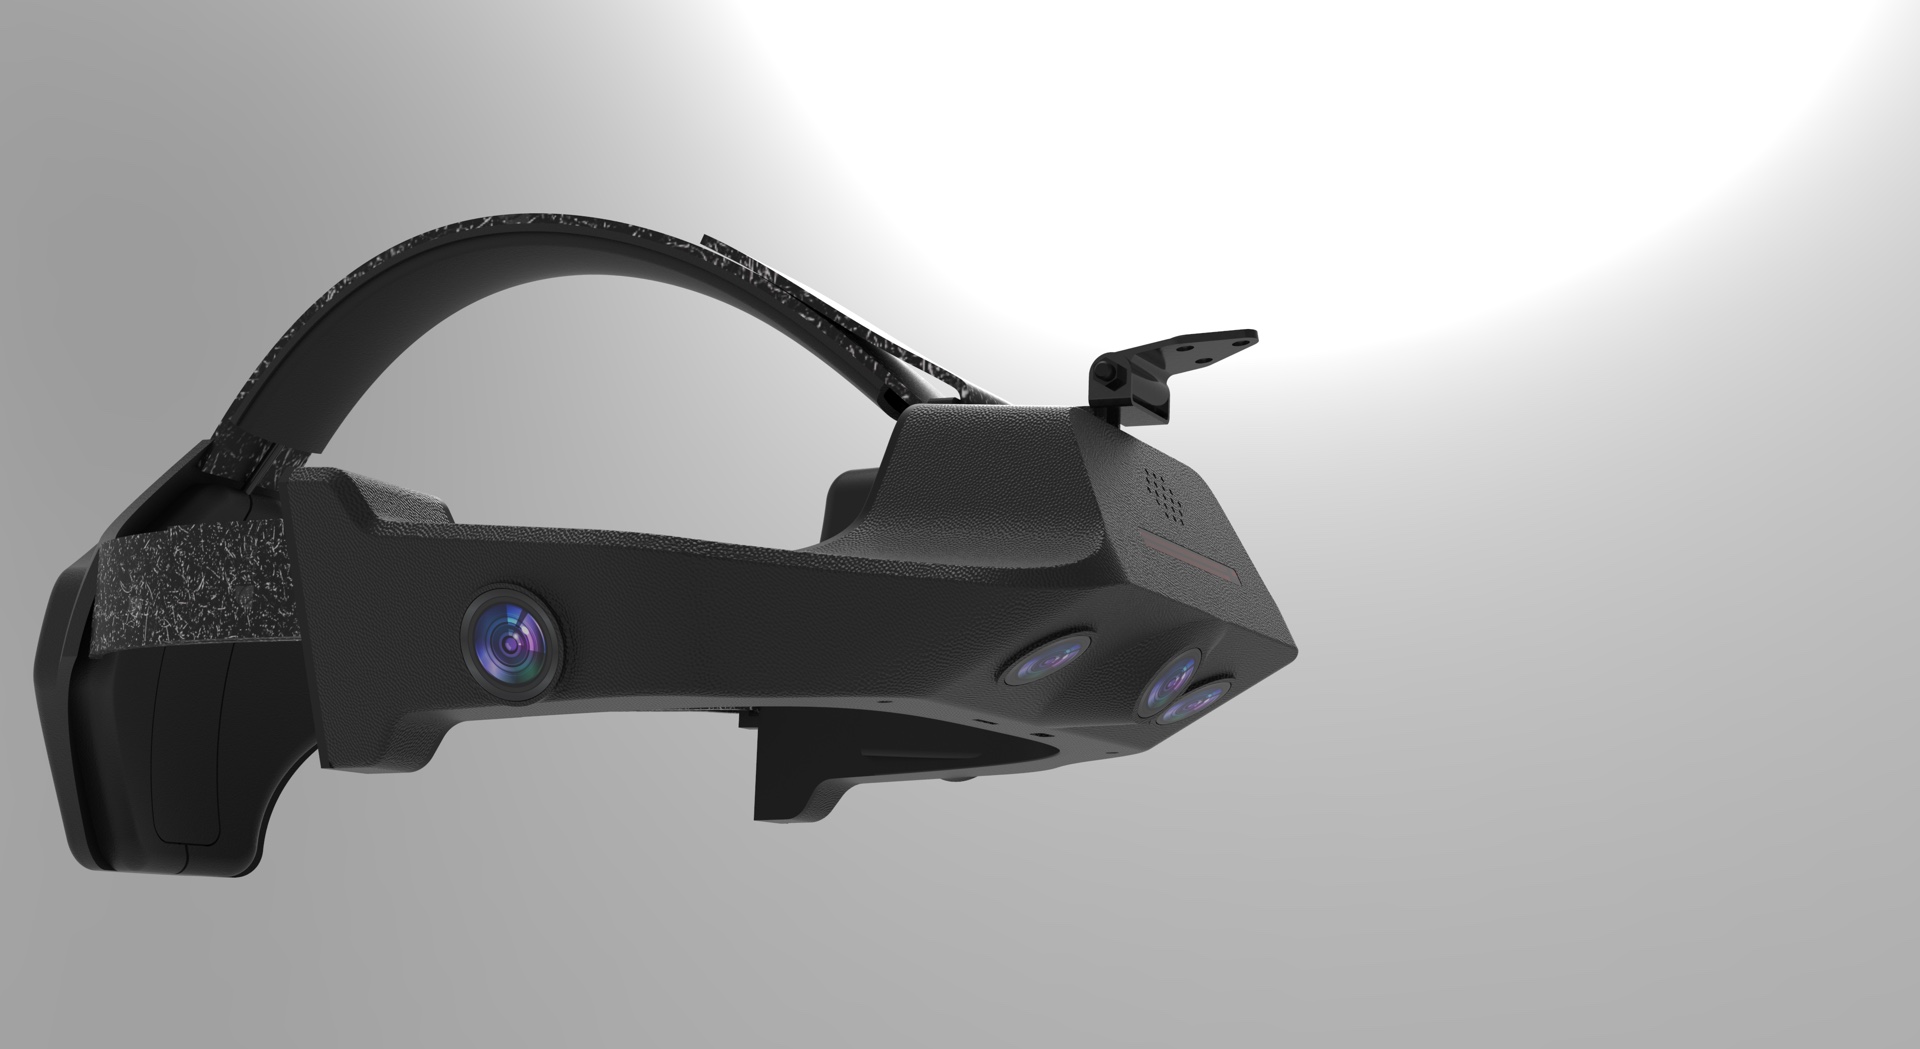
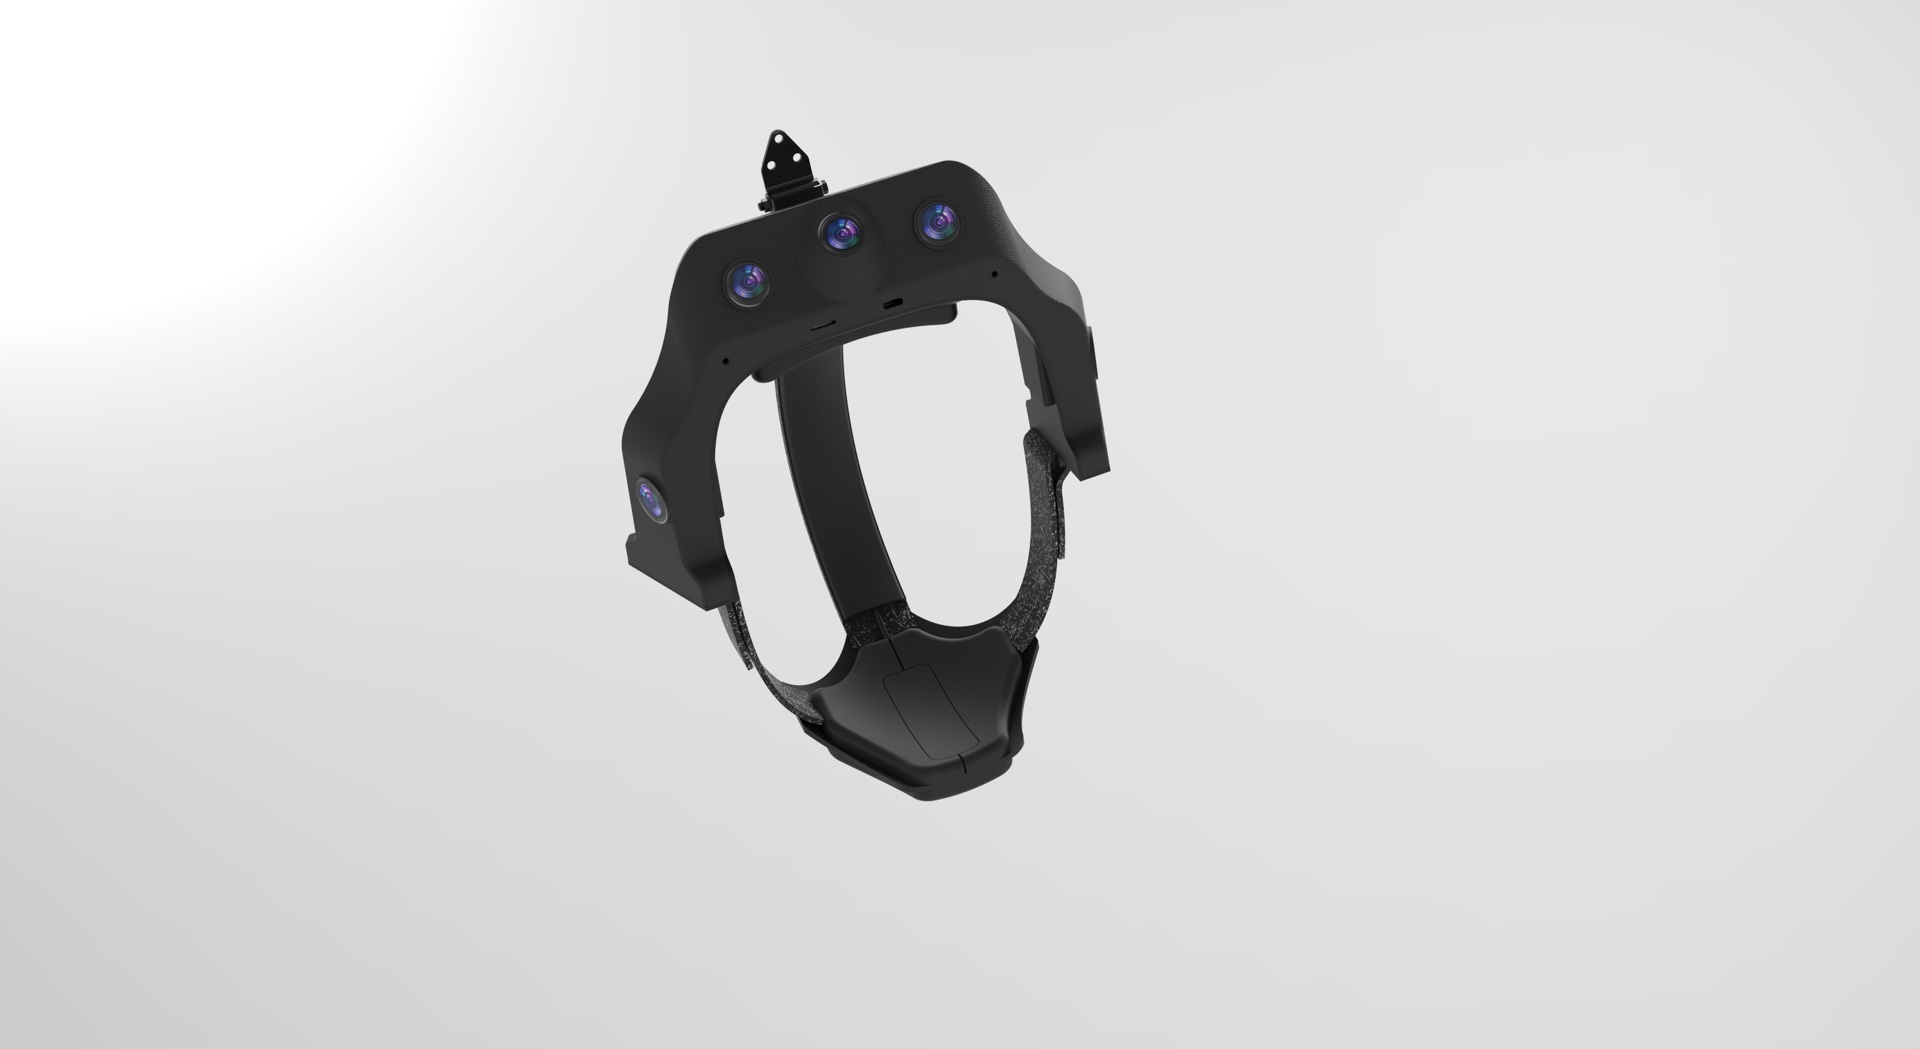
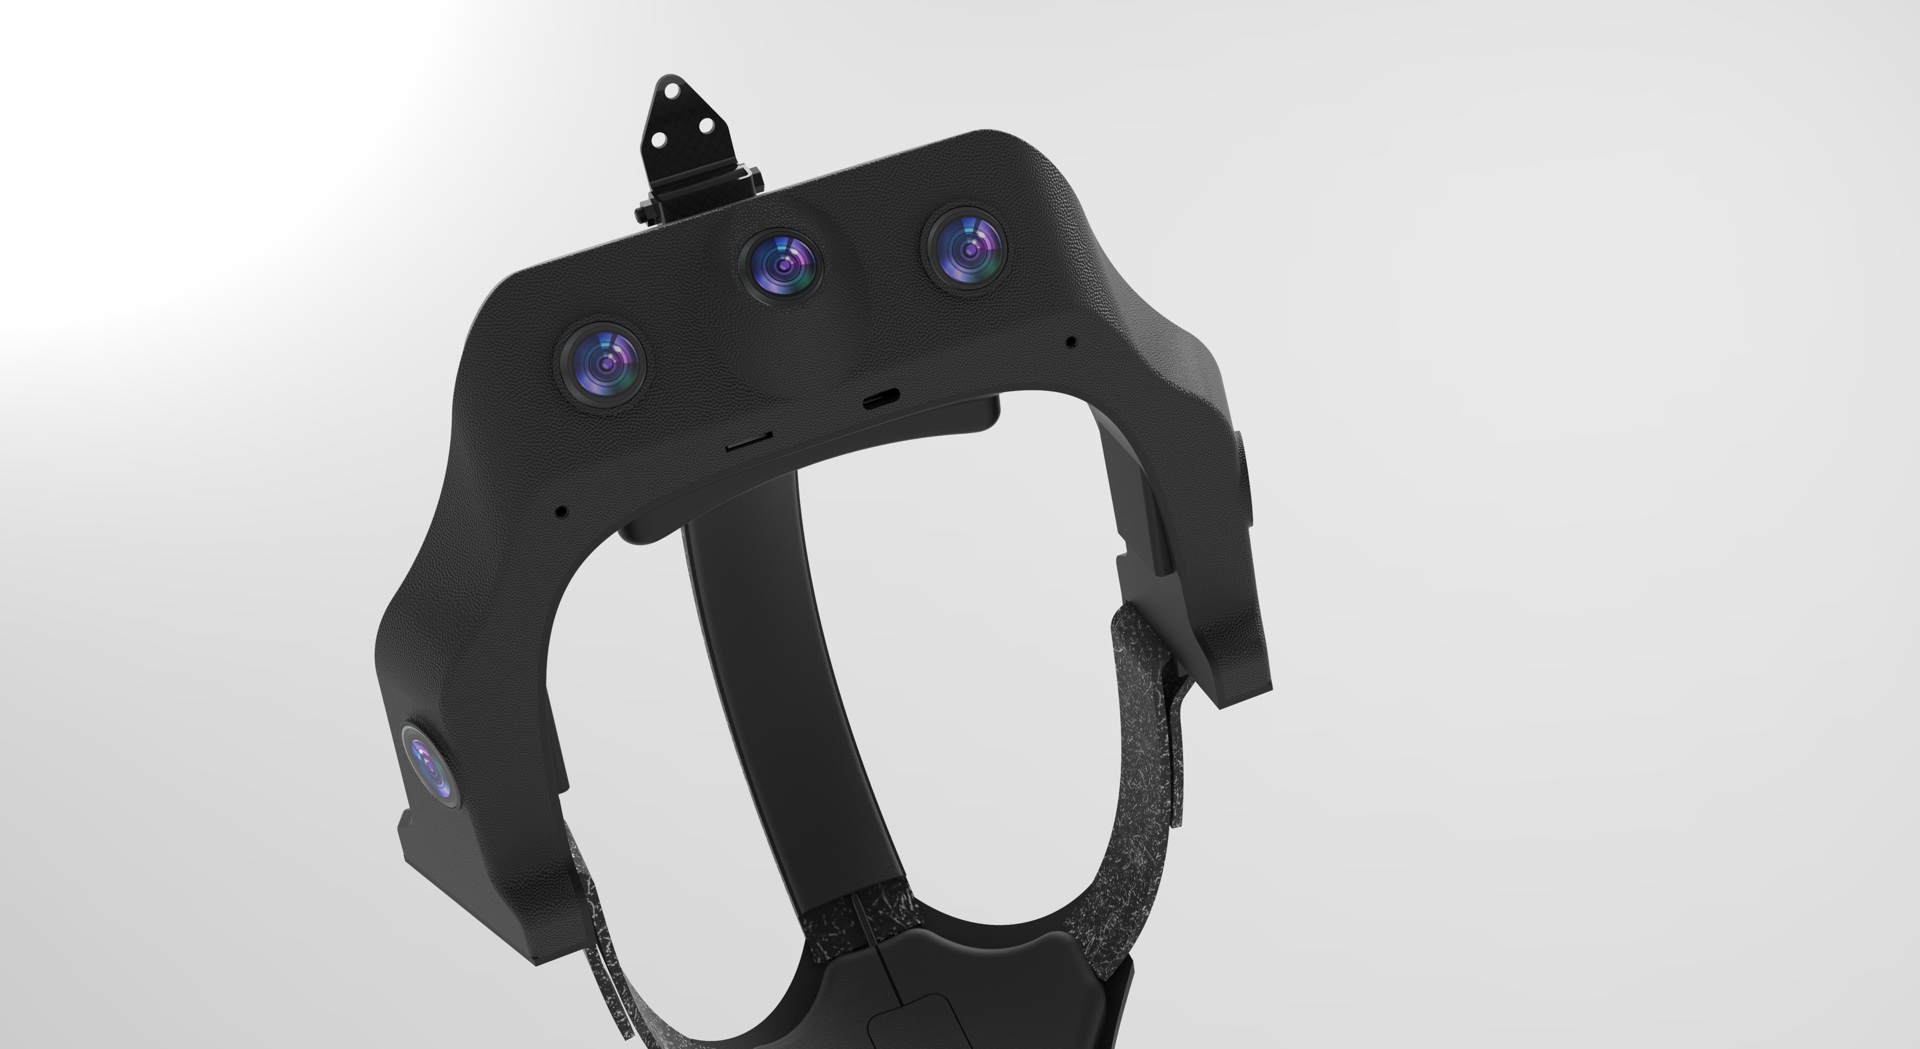
01 Panoramic Motion Capture
Capture every move.Connect to the real world.
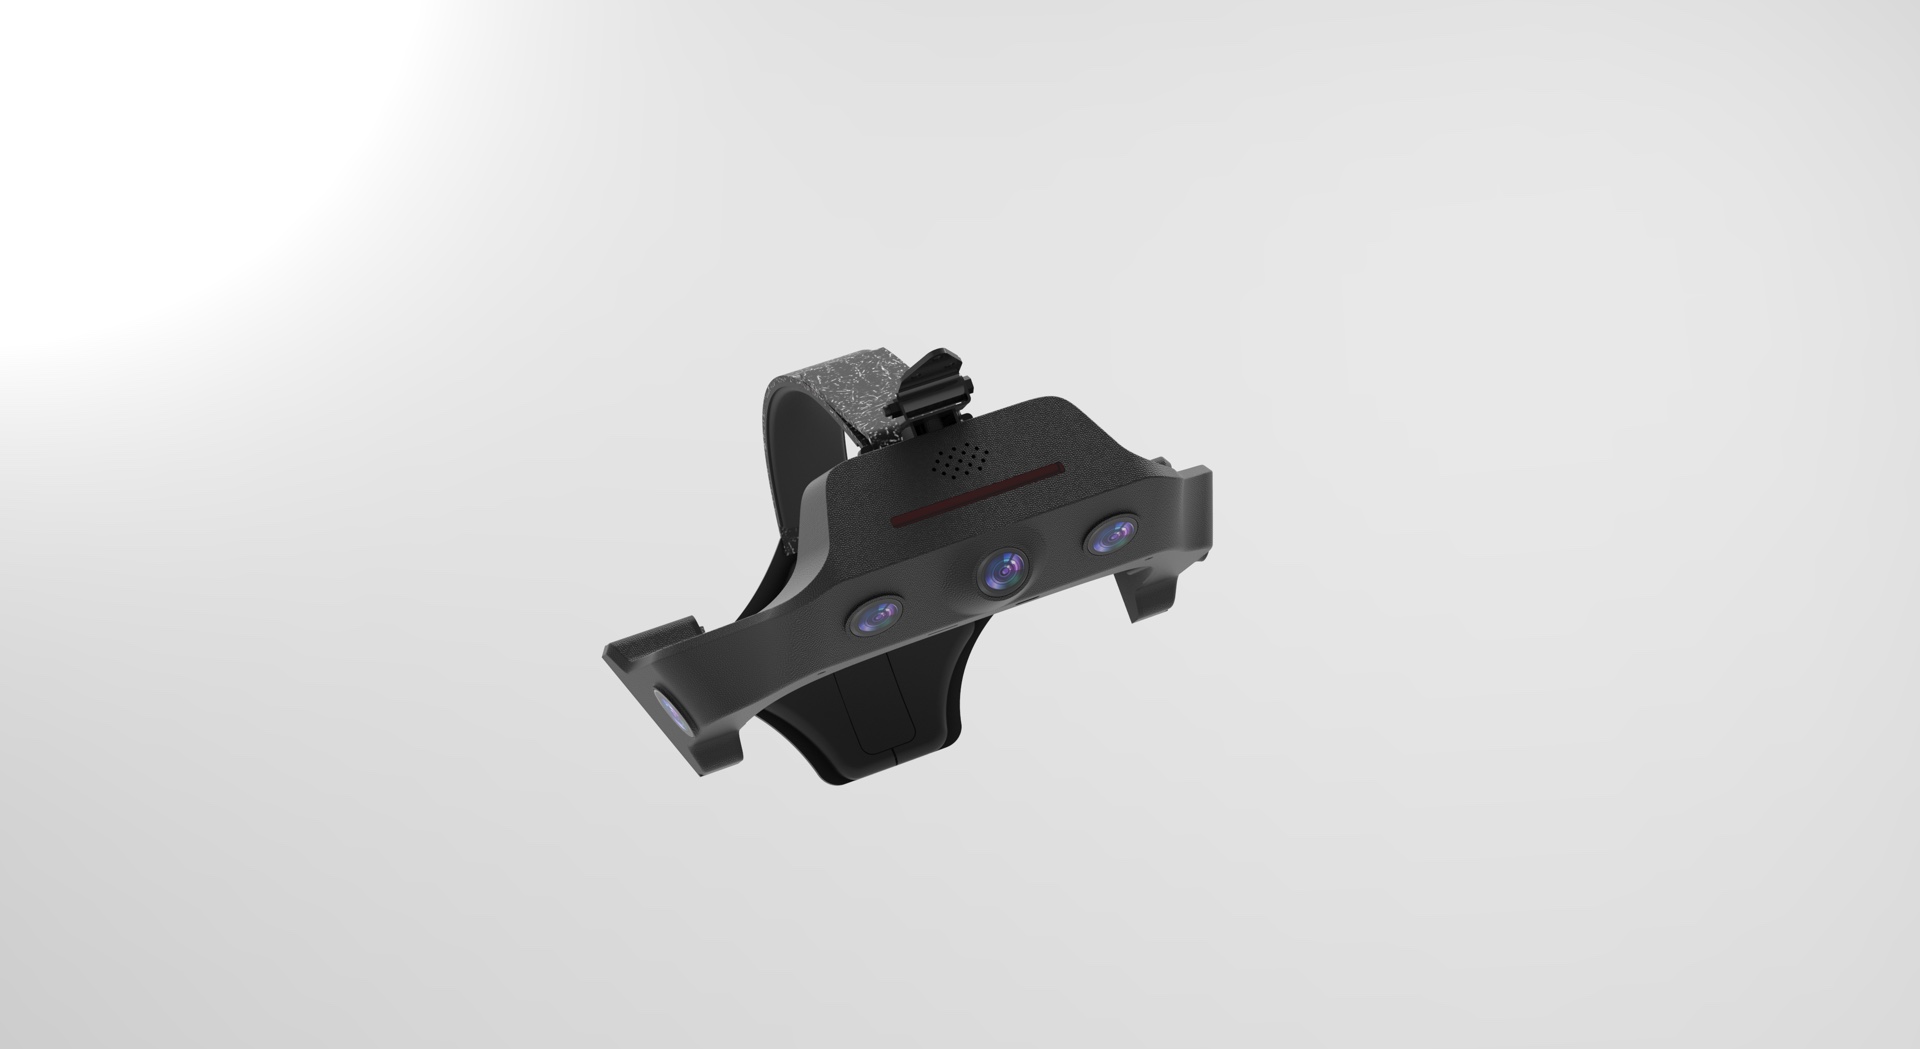
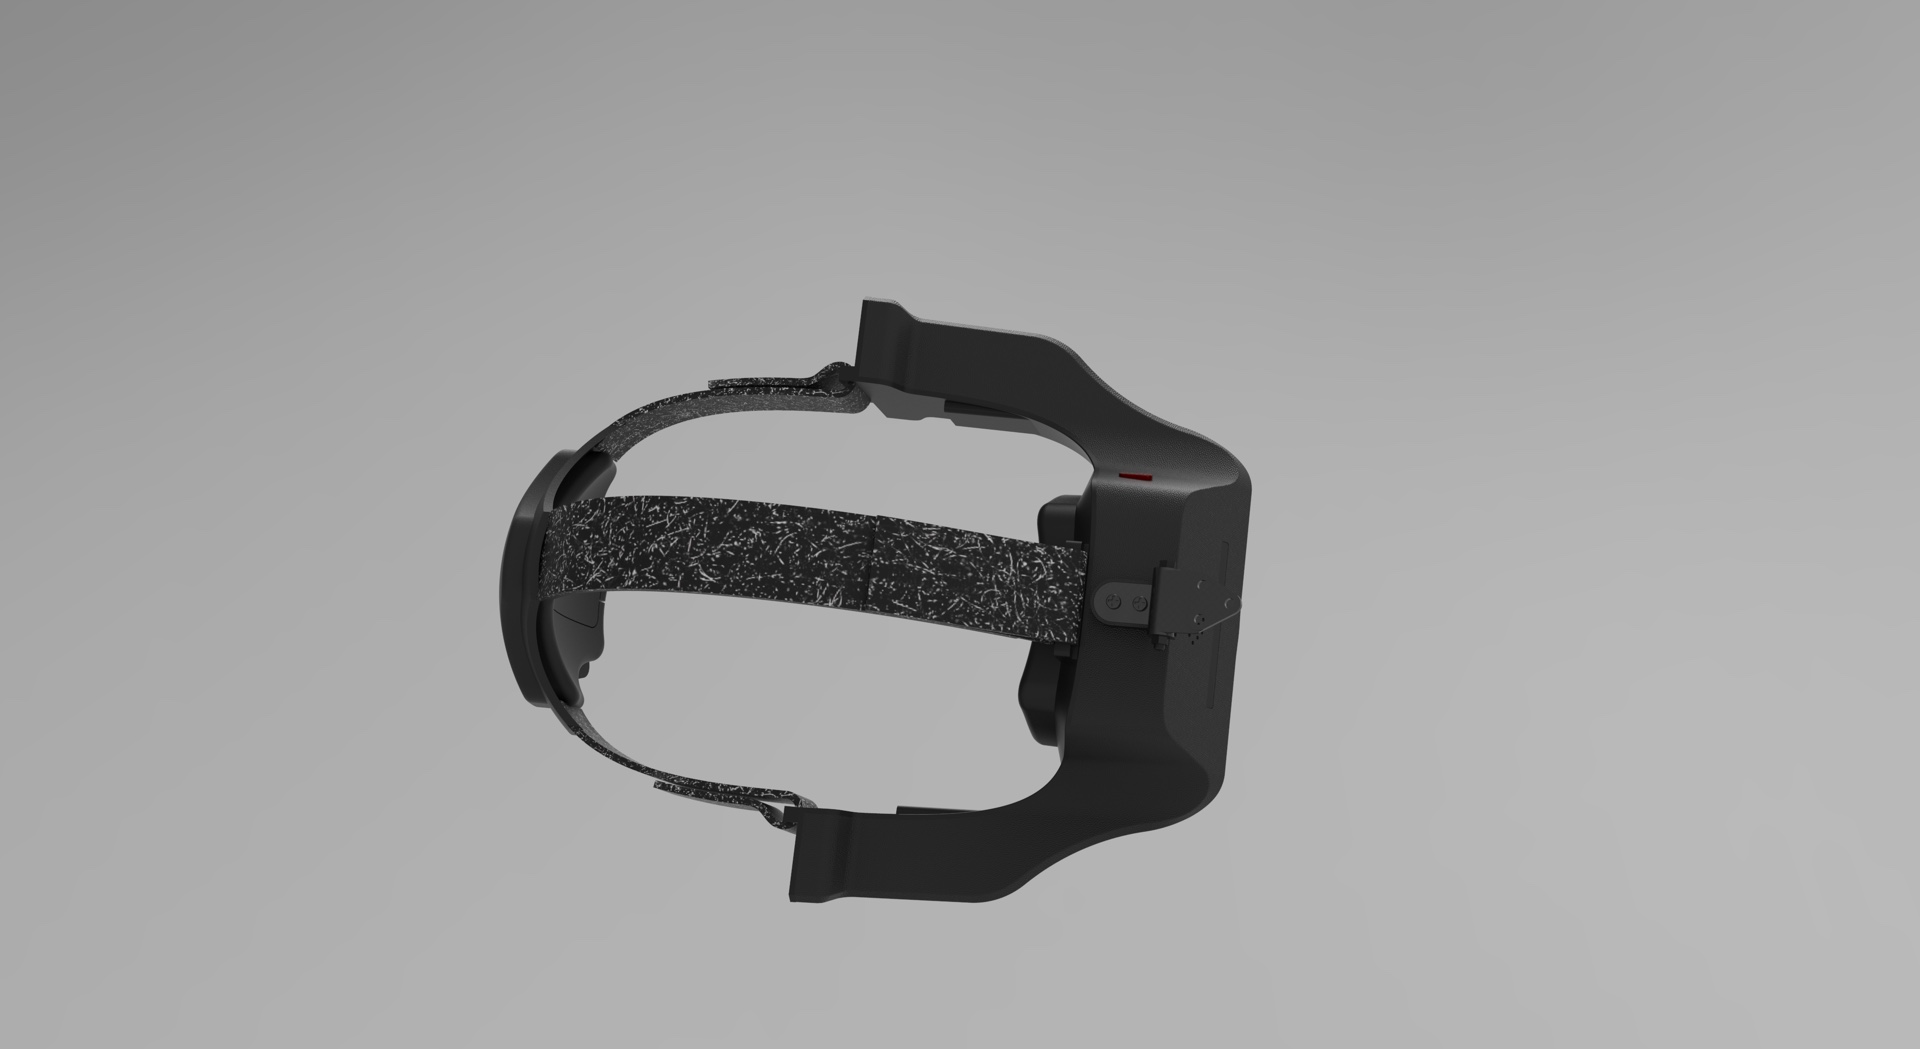
Capture how people interact with their environment from a first-person perspective. Every movement offers a new way to understand the real world.
02 3D Tactile Glove
Beyond seeing.Feel every contact.
A data glove combining fabric-based tactile sensing with motion capture.
This video could not be loaded. Please refresh the page to try again.
03 Egocentric Data
Everyday interactions.Insights into the real world.
An egocentric data annotation flywheel powered by large AI models.
This video could not be loaded. Please refresh the page to try again.
04 5D-Ego Data
See the movement.Feel the contact.
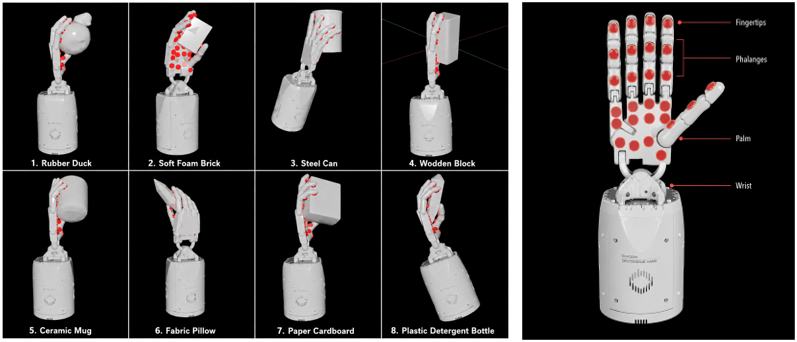
Fusion of tactile, force, vision, motion and semantic data.
05 Tactile World Model
Physical interactions.Made visible in simulation.
Explore contact dynamics and tactile signals through tactile simulation in Isaac Sim.
This video could not be loaded. Please refresh the page to try again.